

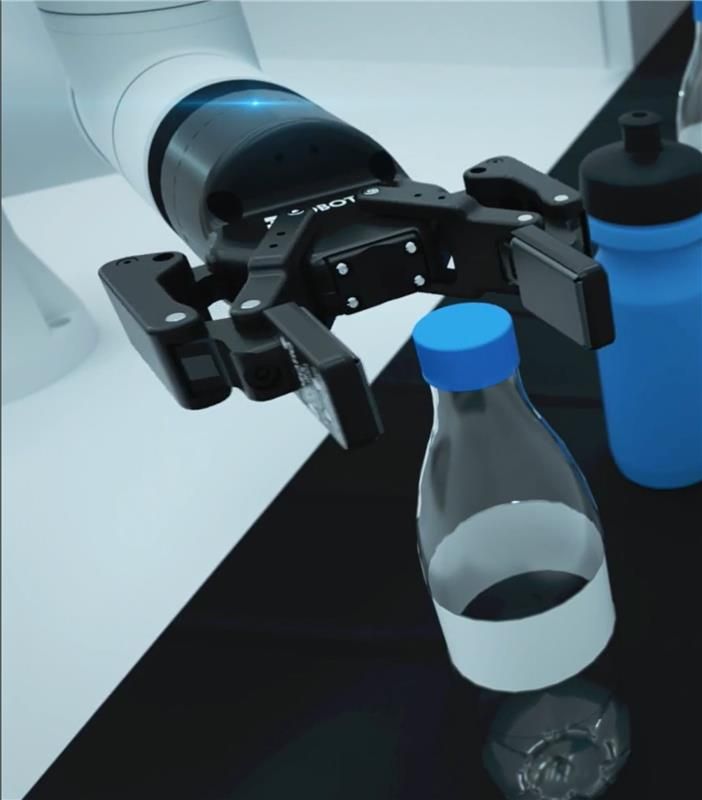
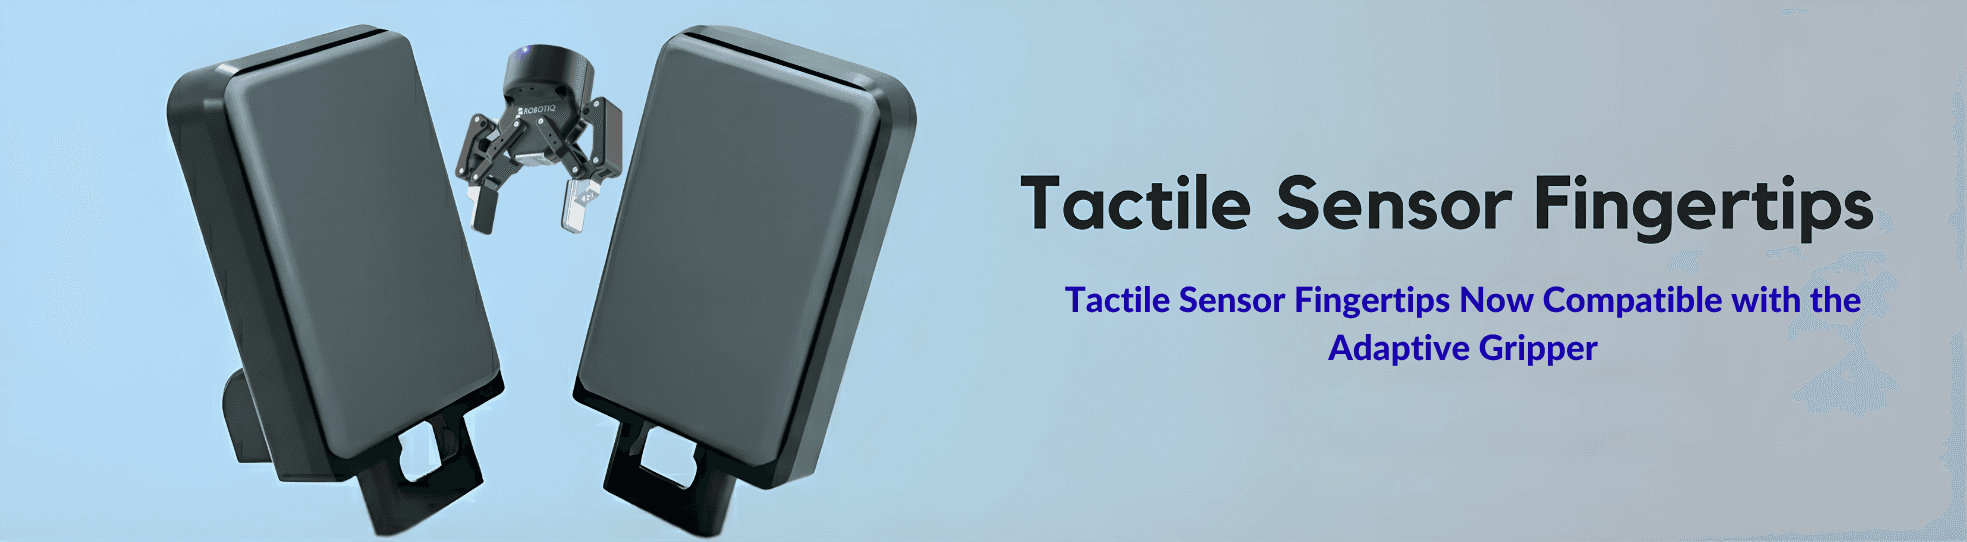
The TSF85 Tactile Sensor Fingertips Robotic Gripper represents a major milestone in robotics by introducing true tactile perception into robotic gripping. With high-precision tactile sensing, real-time force detection, IMU integration, micro-slip monitoring, and ROS2/NVIDIA Isaac Sim compatibility, the TSF85 empowers robots to operate with greater intelligence, adaptability, and human-like dexterity.
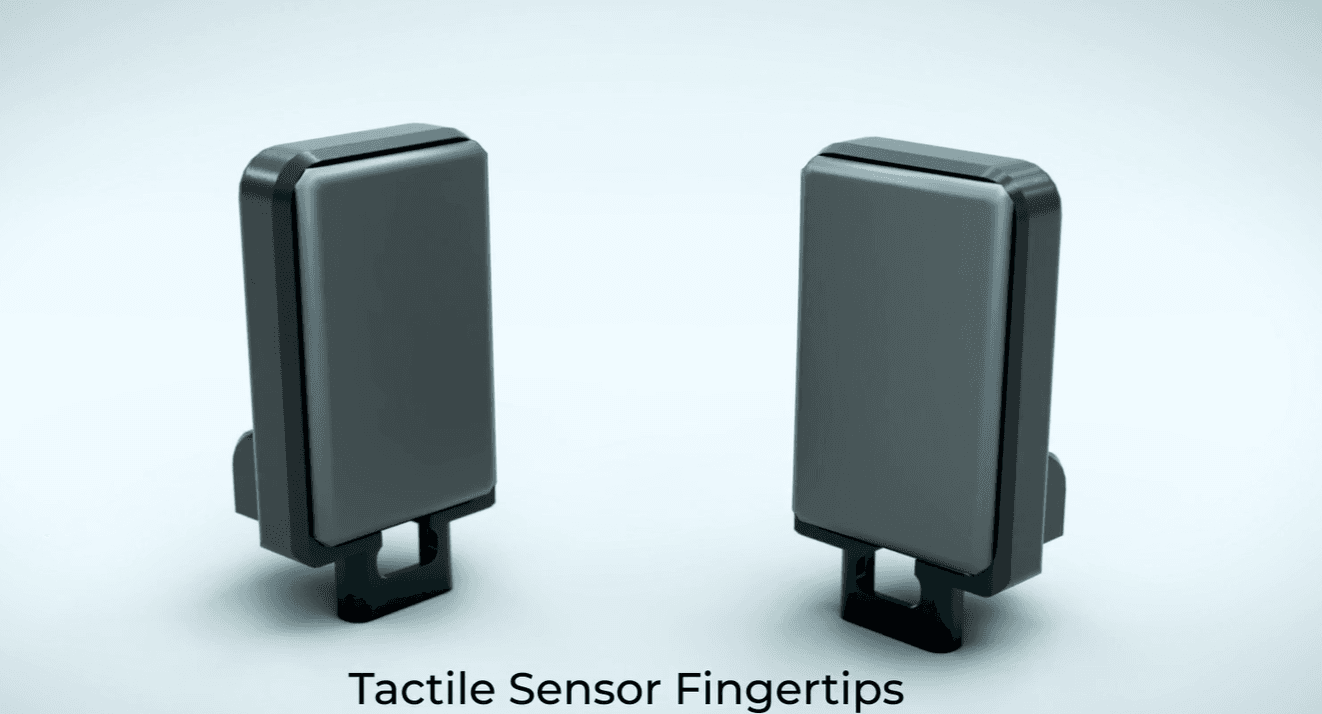
For decades, robotic grippers have employed vision, force sensors, and pre-programmed motion to pick up objects. Conventional robotic gripping is effective in a controlled environment, but not in a real-world scenario where objects vary in shape, texture, weight, and fragility.
The goal of adjusting grip force, detecting slippage, and dealing with fragile objects is, in essence, accomplished through touch. The TSF85 Tactile Sensor Fingertips Robotic Gripper has enabled robots to achieve this capability.
The TSF85 allows robots to pick up objects more intelligently, safely , and precisely using its high-resolution tactile sensing, real-time force measurement, micro-slip detection, and fingertip orientation.
This blog post will explore the technology, specifications, applications, benefits, and potential of the TSF85 robotic gripper.
What is the TSF85 Tactile Sensor Fingertips Robotic Gripper?
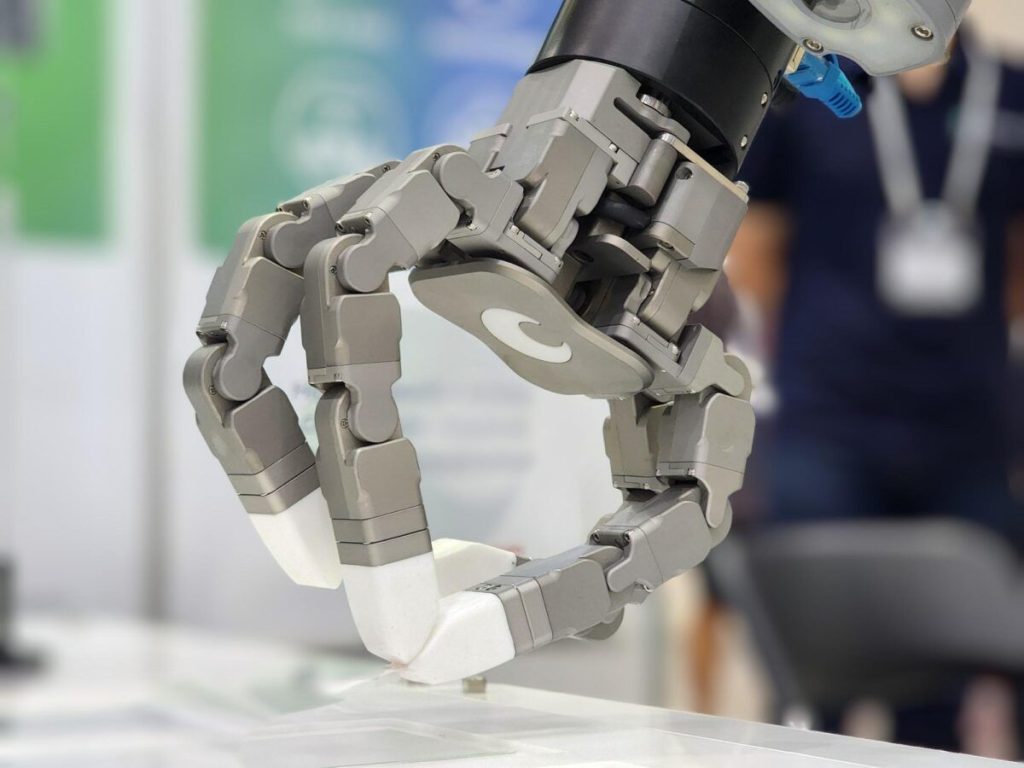
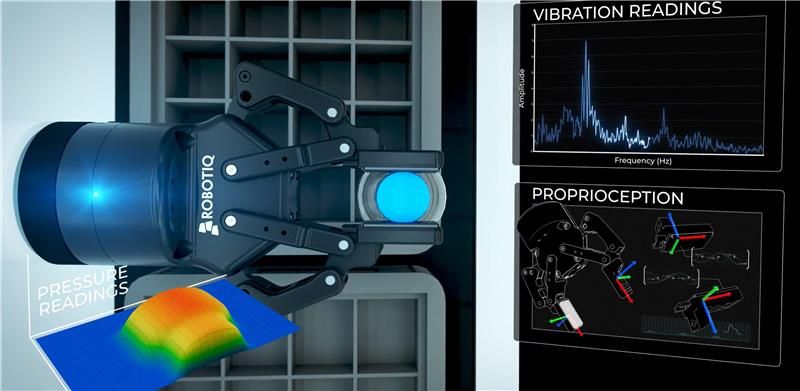
The TSF85 is an advanced robotic gripper with touch-sensitive fingertips that provide real-time feedback on vibrations, slide actions, pressure distribution, and force of contact.
Unlike traditional grippers, which rely solely on force or position, the TSF85 enables touch-sensitive manipulation, allowing robots to:
– Detect if something is understood
– Adjust dynamic grip pressures
– Identify grips that are fragile or sliding
– Manipulate deformable or fragile objects safely
.
It is for this reason that the TSF85 is ideal for use in automation, research, logistics, healthcare, electronics, manufacturing , and AI robots.
The TSF85 Robotic Gripper’s key features
1. 4×7 Sensor Array for High-Precision Tactile Sensing
The key feature of the TSF85 is the 4×7 tactile sensor array, which allows for high-precision pressure and touch mapping on the fingertip surface.
Key advantages:
– Locates precise contact points
– Estimates not only the net grip force but also the distributed force.
– Detects interactions on the detailed surface
– Enables adaptive grip control.
This allows robots to respond intelligently to a range of object shapes and materials, from soft packaging to hard metal parts.
2. Extremely Fast Data Sampling (1000 Hz)
The TSF85 is capable of real-time data sampling of its tactile sensors at a rate of 1000 Hz.
This fast sensing enables:
– Fast detection of micro-slips
– Fast grip changes
– Closed-loop control with real-time feedback
– More sensitive and natural robotic movements
The result is human-like reaction speed, improving both safety and precision.
3. Identification of Micro-Slips and Contact Forces
Among the most complex functionalities of the TSF85 is its ability to:
– Calculate the magnitude of the contact force
– Calculate the start of a slide
– Monitor micro-slips before the object falls.
This helps robots to:
– The gripping force should be raised only when needed.
– Prevent dropping objects
– Reduce over-gripping that may damage delicate objects.
This is especially true in industries such as food processing, medical automation, and electronics production.
4. Integrated IMU for Vibrations and Fingertip Orientation
The TSF85’s integrated Inertial Measurement Unit (IMU) monitors:
– The orientation of the fingertips
– The dynamics of motion
– The vibrations when in contact
– The trends in the movement of the object
This enhances the ability of robots to perform dynamic tasks by allowing them to understand the motion of an object rather than the force with which it is being held.
How TSF85 Transforms Robotic Gripping
1. From Blind Gripping to Touch-Aware Manipulation
Conventional grippers do not comprehend the texture of the object being gripped. The TSF85 enables robots to:
– Detect when contact is made
– Adjust grip pressure automatically
– Detect when an object is about to tip over
This enables more intelligent and safe manipulation of objects by robots.
2. Better Handling of Delicate and Irregular Objects
Using touch sensing, robots can handle:
– Glassware
– Soft food products
– Medical instruments
– Electronic devices
– Thin plastic packaging
3. Higher Success Rates for Pick-and-Place Tasks
With slip detection and grip force optimization, the TSF85:
– Reduces the rate of failed attempts to grasp
– Prevents items from being tipped
– Raises the rate of high-speed automation lines
– The efficiency of operation is directly improved.
4. Unlocking Robotic Touch with AI and Machine Learning
Trained AI models can be developed based on the TSF85’s touch information to:
– Categorize objects by touch
– Find optimal gripping methods
– Without modification, adapt to new objects
– This paves the way for self-learning robots.
Technical Advantages at a Glance
| Feature | Benefit |
|---|---|
| 4×7 tactile sensor array | High-resolution contact detection |
| 1000 Hz sampling rate | Real-time, fast reaction |
| Micro-slip detection | Prevents object drops |
| Built-in IMU | Orientation & vibration tracking |
| RS-485 / USB | Easy hardware integration |
| ROS2 & NVIDIA Isaac Sim support | AI-ready & simulation compatible |
Competitive Edge of TSF85 Over Traditional Grippers
| Feature | Traditional Grippers | TSF85 Tactile Gripper |
|---|---|---|
| Sensing Type | Force-based only | Force + tactile sensing |
| Slip Detection | No slip detection | Real-time slip detection |
| Grip Strategy | Fixed grip strategy | Adaptive grip control |
| AI Compatibility | Limited AI feedback | AI & ML ready |
| Dexterity | Lower dexterity | Human-like touch response |
Conclusion A New Era of Touch-Enabled Robotics
The TSF85 Tactile Sensor Fingertips Robotic Gripper represents a major milestone in robotics by introducing true tactile perception into robotic gripping.
With high-precision tactile sensing, real-time force detection, IMU integration, micro-slip monitoring, and ROS2/NVIDIA Isaac Sim compatibility, the TSF85 empowers robots to operate with greater intelligence, adaptability, and human-like dexterity.
For industries seeking higher automation reliability, better handling of delicate objects, reduced errors, and AI-ready robotic systems, the TSF85 is a game-changing solution.